Project 01
Efsyco
Autonomous fixed-wing aerial solutions for GPS-denied operation
- Project
- Efsyco
- Role
- Co-founder
- Organisation
- Efsyco
- Period
- 2025–
- Dwg no.
- CVW-01
- Rev
- B
1Problem
Drones used for inspection, infrastructure and other demanding missions typically depend on GPS. Where GPS is degraded, jammed or simply unavailable, that dependency breaks the mission.
Efsyco builds autonomous fixed-wing aerial solutions that keep operating reliably in GPS-denied environments.
2My role
Co-founder. On the business side: market research and customer discovery. On the technical side: software development on the visual navigation stack.
3System overview
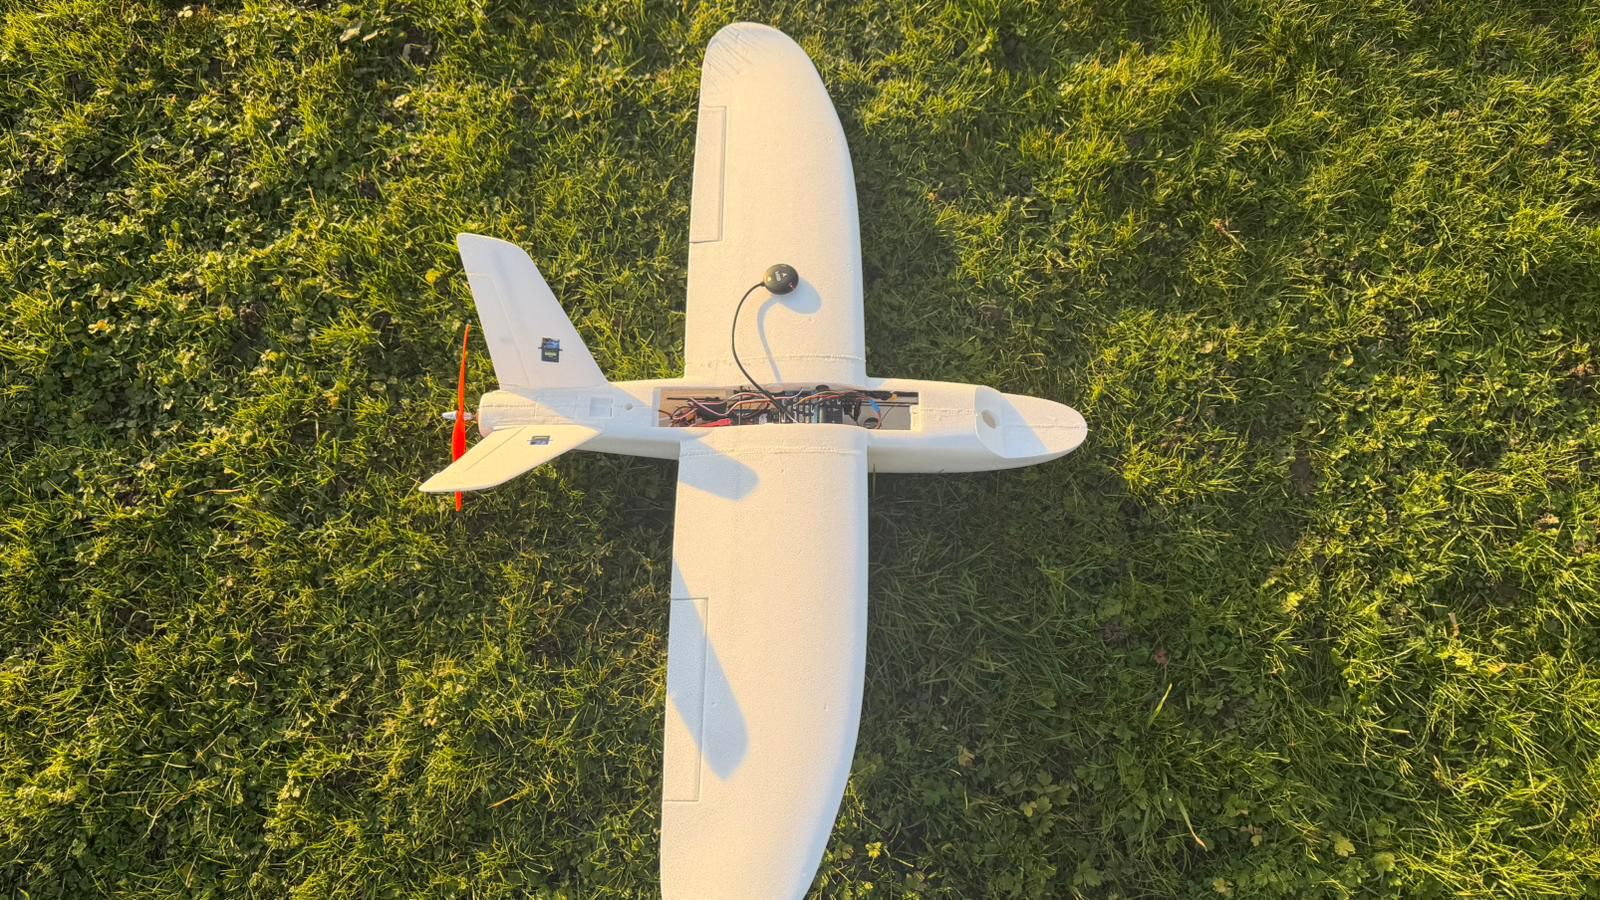
A fixed-wing UAV that navigates autonomously without relying on GPS. The platform is chosen for efficiency and endurance, so that a single aircraft can carry out long-distance autonomous tasks.
| Parameter | Value |
|---|---|
| Platform | Fixed-wing UAV |
| Navigation | Autonomous, designed for GPS-denied environments |
| Design driver | Efficiency and endurance for long-distance autonomous tasks |
| My focus | Visual navigation stack · market research · customer discovery |
| Status | Flying prototype — first flight in May |
4Key decisions & trade-offs
- 4.1
Fixed-wing over multirotor
A fixed-wing aircraft flies far more efficiently than a multirotor, which is what long-distance autonomous missions need. The price is that it cannot hover, so the mission and the navigation have to be designed around continuous forward flight.
- 4.2
Navigation that does not depend on GPS
The navigation stack is built for environments where GPS cannot be trusted, rather than treating GPS loss as an edge case — which is why the visual navigation stack is a core part of the system.
5Results
- Winner of the Startup Campus Innosuisse Prize, 2024.
- First flight of the prototype in May.
6Media